IROS 2026 · Pittsburgh, PA arXiv:2607.00141 GitHub F1TENTH Gym

AD-MPCC: Adaptive Differentiable Model Predictive Contouring Control for Autonomous Racing
Nam T. Nguyen1,†   Binh Nguyen1,†   Ahmad Amine2   Thanh Vo-Duy3   Rahul Mangharam2   Truong X. Nghiem1
Racing Demos Read on arXiv GitHub Repo
1 University of Central Florida logo University of Central Florida 2 University of Pennsylvania logo University of Pennsylvania 3 Hanoi University of Science and Technology logo Hanoi University of Science and Technology

How it works

AD-MPCC combines two components operating at each time step:
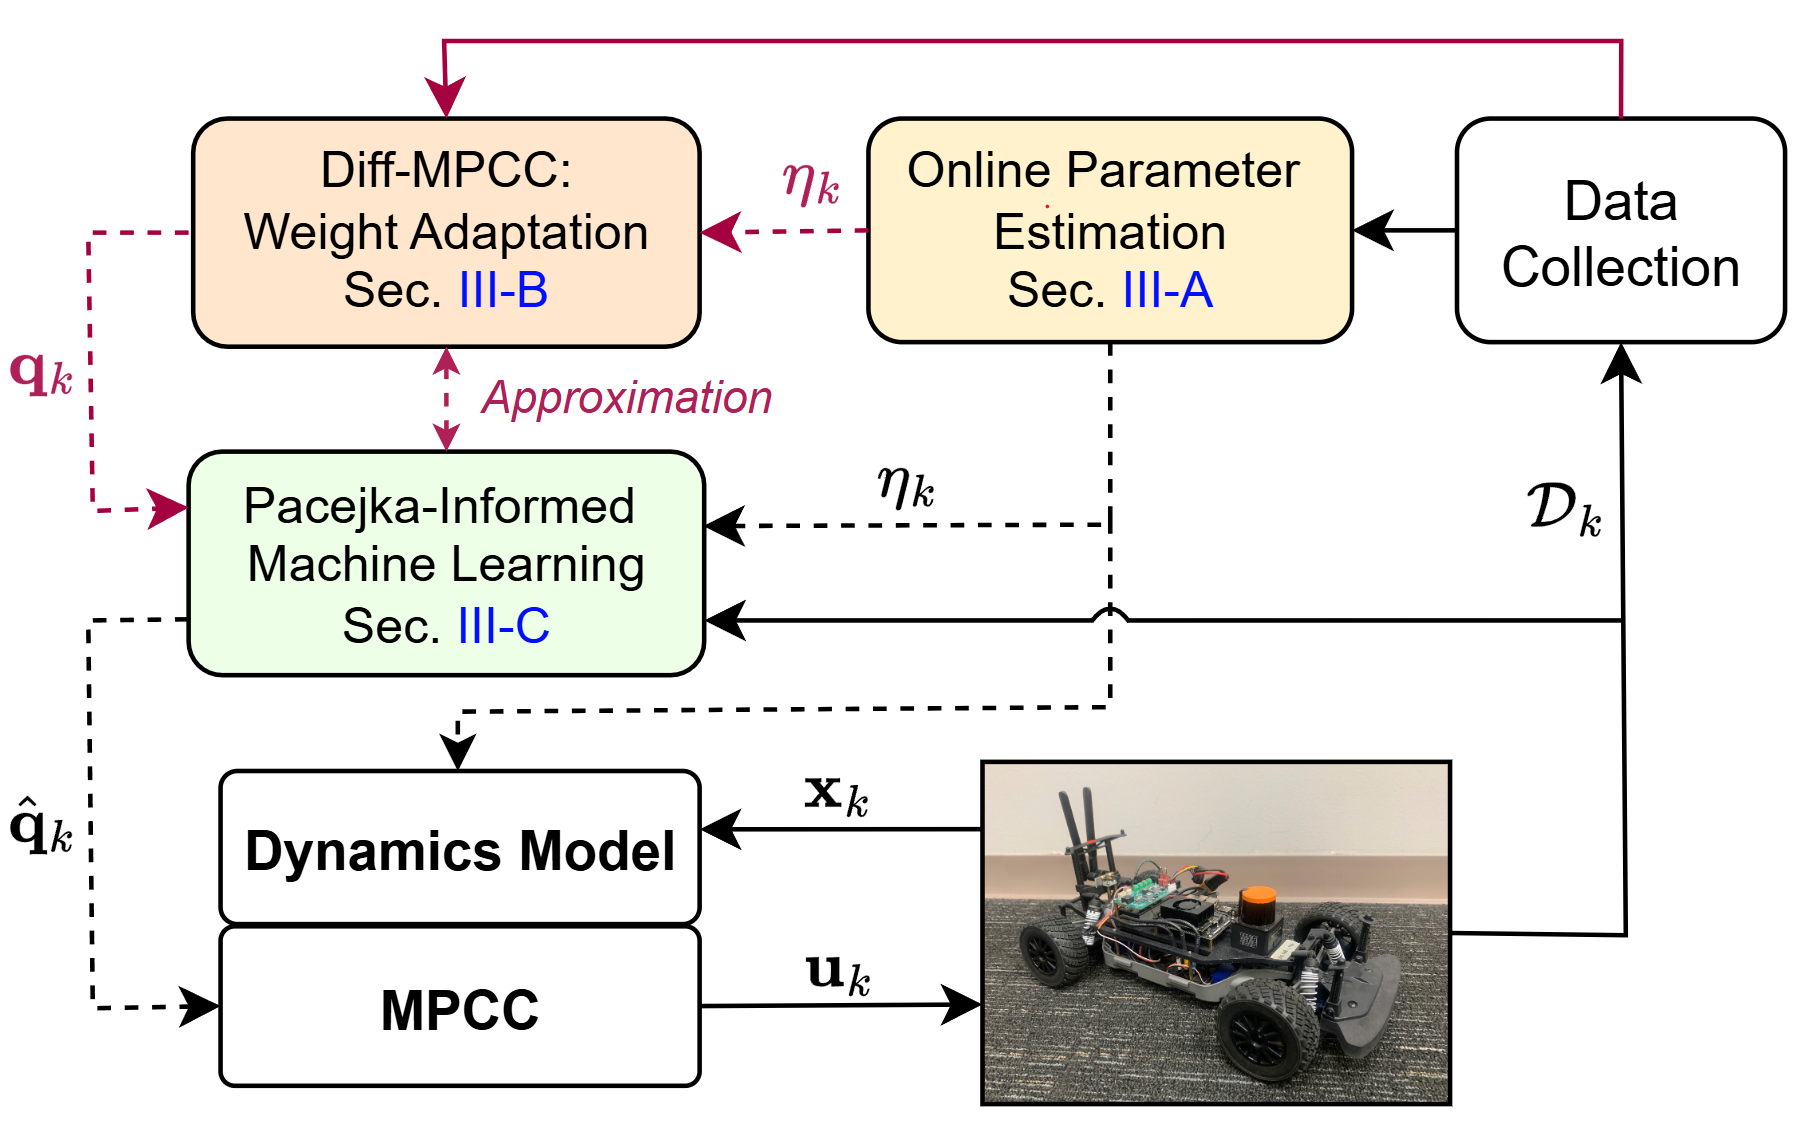
AD-MPCC architecture

Single-Surface Scenario

All four controllers are evaluated on a uniform road surface with μmax = 1.2 for 10 laps. Diff-MPCC and AD-MPCC achieve approximately 11 s faster lap times than the baseline MPCC by adapting the objective weights online, while AD-MPCC further maintains the smallest mean lateral offset (0.926 m), demonstrating a better safety–speed trade-off.

MPCC
A-MPCC
Diff-MPCC
AD-MPCC (ours)

Avg. Lap Time

seconds · ↓ lower is better
MPCC
75.57 s
A-MPCC
75.62 s
Diff-MPCC
64.08 s
AD-MPCC
64.89 s

Avg. Longitudinal Speed

m/s · ↑ higher is better
MPCC
11.38
A-MPCC
11.41
Diff-MPCC
13.59
AD-MPCC
13.50

Avg. Lateral Offset

meters · ↓ lower is better
MPCC
1.953 m
A-MPCC
1.815 m
Diff-MPCC
1.040 m
AD-MPCC
0.926 m
View exact numbers as a table
ControllerAvg. Lap Time (s)Avg. v_x (m/s)Avg. Lateral Offset (m)Avg. Comp. Time (ms)
MPCC75.5711.381.95320.45
A-MPCC75.6211.411.81521.21
Diff-MPCC64.0813.591.04023.56
AD-MPCC64.8913.500.92624.18

Multi-Surface Scenario

The track surface varies from μmax = 0.7 to 1.2 across different sections. Only AD-MPCC successfully completes the lap by jointly updating Pacejka parameters and MPCC weights in real time, while MPCC, A-MPCC, and Diff-MPCC all crash at the first slippery segment (μmax = 0.75) due to insufficient adaptation.
MPCC
✕ Crashed at μ = 0.75
A-MPCC
✕ Crashed at μ = 0.75
Diff-MPCC
✕ Crashed at μ = 0.75
AD-MPCC (ours)
✓ Completed the lap
Lap time 74.9 s
Avg. v_x 11.65 m/s
Lateral offset 1.069 m

BibTeX

@misc{nguyen2026admpccadaptivedifferentiablemodel, title={AD-MPCC: Adaptive Differentiable Model Predictive Contouring Control for Autonomous Racing}, author={Nam T. Nguyen and Binh Nguyen and Ahmad Amine and Thanh Vo-Duy and Rahul Mangharam and Truong X. Nghiem}, year={2026}, eprint={2607.00141}, archivePrefix={arXiv}, primaryClass={cs.RO}, url={https://arxiv.org/abs/2607.00141}, }
← More from Nam Nguyen